Hi! Welcome to my homepage. I’m Yaming Ou (欧亚明), an Assistant Researcher at the Tactile Perception and Embodied Manipulation Laboratory, School of Artificial Intelligence, University of Chinese Academy of Sciences (UCAS), working with Prof. Long Cheng (IEEE Fellow). I received my Ph.D. from the C2DL Lab, Institute of Automation, Chinese Academy of Sciences (CASIA), and UCAS, supervised by Prof. Chao Zhou and Assoc. Prof. Junfeng Fan.
I was a visiting scholar at the Robotics Institute, Carnegie Mellon University, working with Prof. Howie Choset in the Biorobotics Lab from March 2025 to March 2026. Previously, I received my B.E. in Robotics Engineering from Southeast University (ranked 2/34; Outstanding Graduate Award).
My research interests include SLAM, physical intelligence, spatial intelligence, and tactile-based mobile manipulation. My work aims to develop robotic systems endowed with perception, localization, autonomous mobility, and unmanned operation capabilities for extreme real-life applications. Feel free to contact me to discuss robotics and research collaborations.
🔥 News
- 2026.09: Serving as an Associate Editor for Advanced Bionics (ABS).
- 2026.09: Serving as an Associate Editor for ICRA 2027.
- 2026.09: Invited to review 3D Gaussian Splatting research for Science China Information Sciences.
- 2026.07: Invited to review whole-body control research for IEEE Transactions on Automation Science and Engineering.
- 2026.07: Invited to review robot navigation research for IEEE Transactions on Intelligent Vehicles.
- 2026.06: HybridSplat, work with my first supervised student, accepted by IROS 2026. Congratulations to Song!
- 2026.05: Our work on event-based underwater 3D reconstruction accepted by IEEE/ASME Transactions on Mechatronics.
- 2026.04: Successfully defended my Ph.D. and received the CAS President’s Excellence Award (中国科学院院长优秀奖).
📝 Publications
* Corresponding author; † equal contribution. See also Google Scholar.
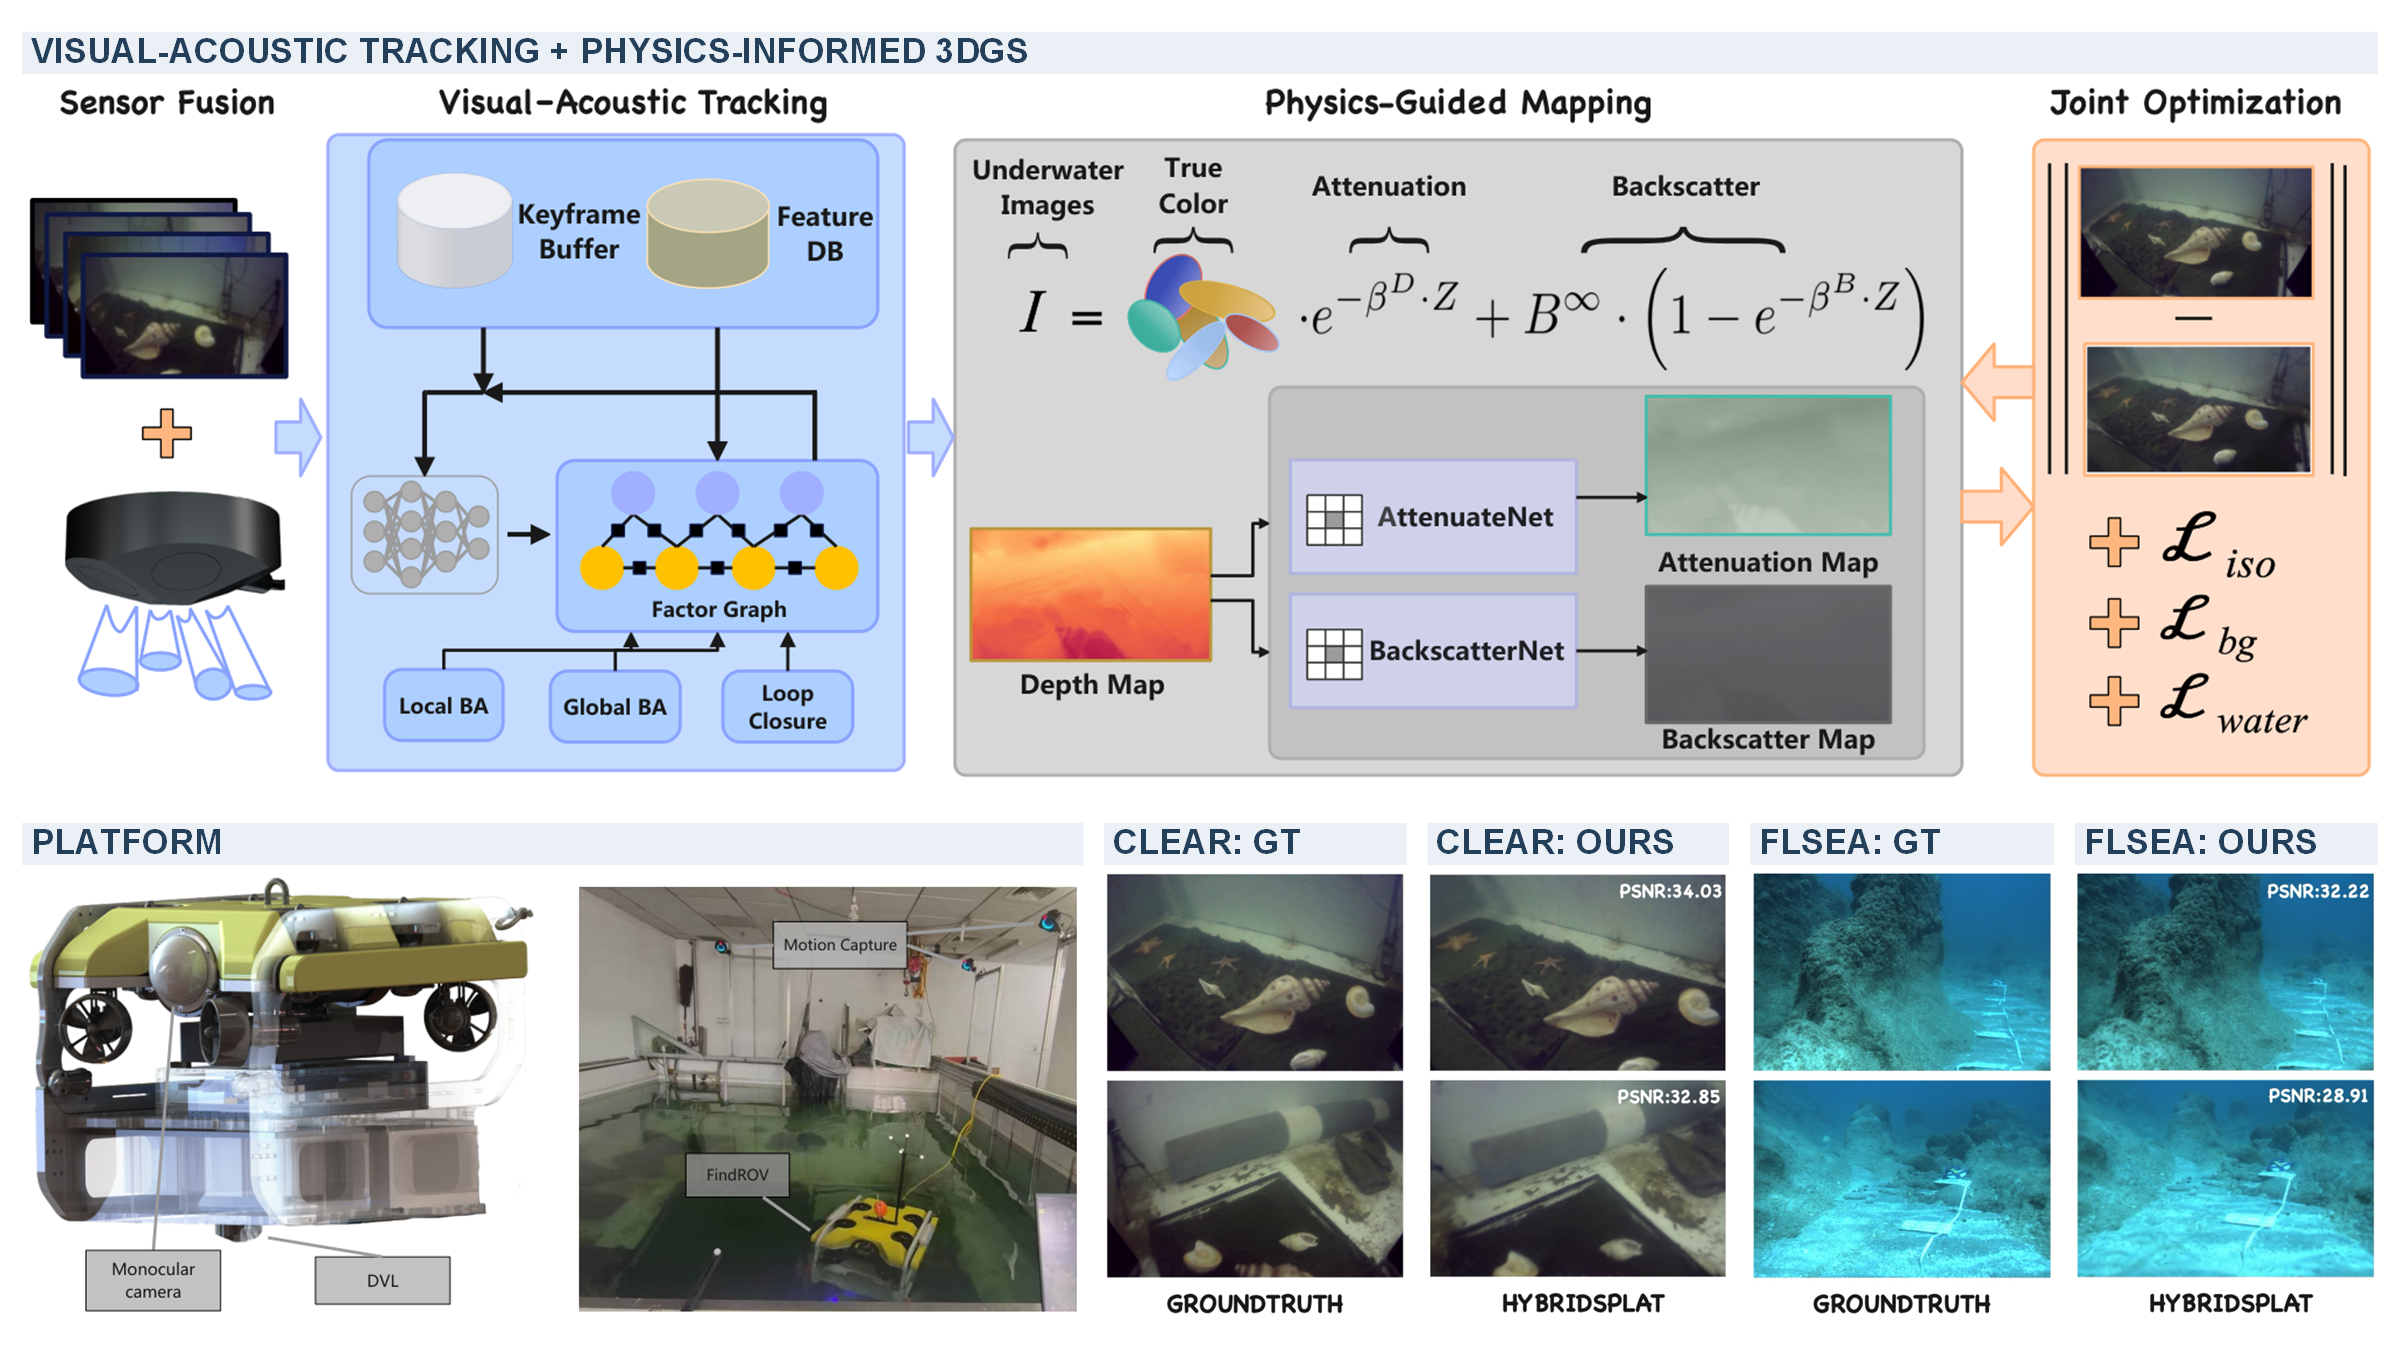
HybridSplat: Underwater Dense SLAM via Visual-Acoustic Fusion and Physics-Informed 3D Gaussian Splatting
Combines DVL-constrained metric tracking with physics-informed 3D Gaussian Splatting to jointly estimate scene geometry and underwater attenuation and backscatter.
Song Xia†, Yaming Ou*†, Junfeng Fan, Chao Zhou, Pengju Zhang, Xiaoyan Liu, Xintao Wang, Xiangyu Sun, Zongyuan Shen. IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2026.
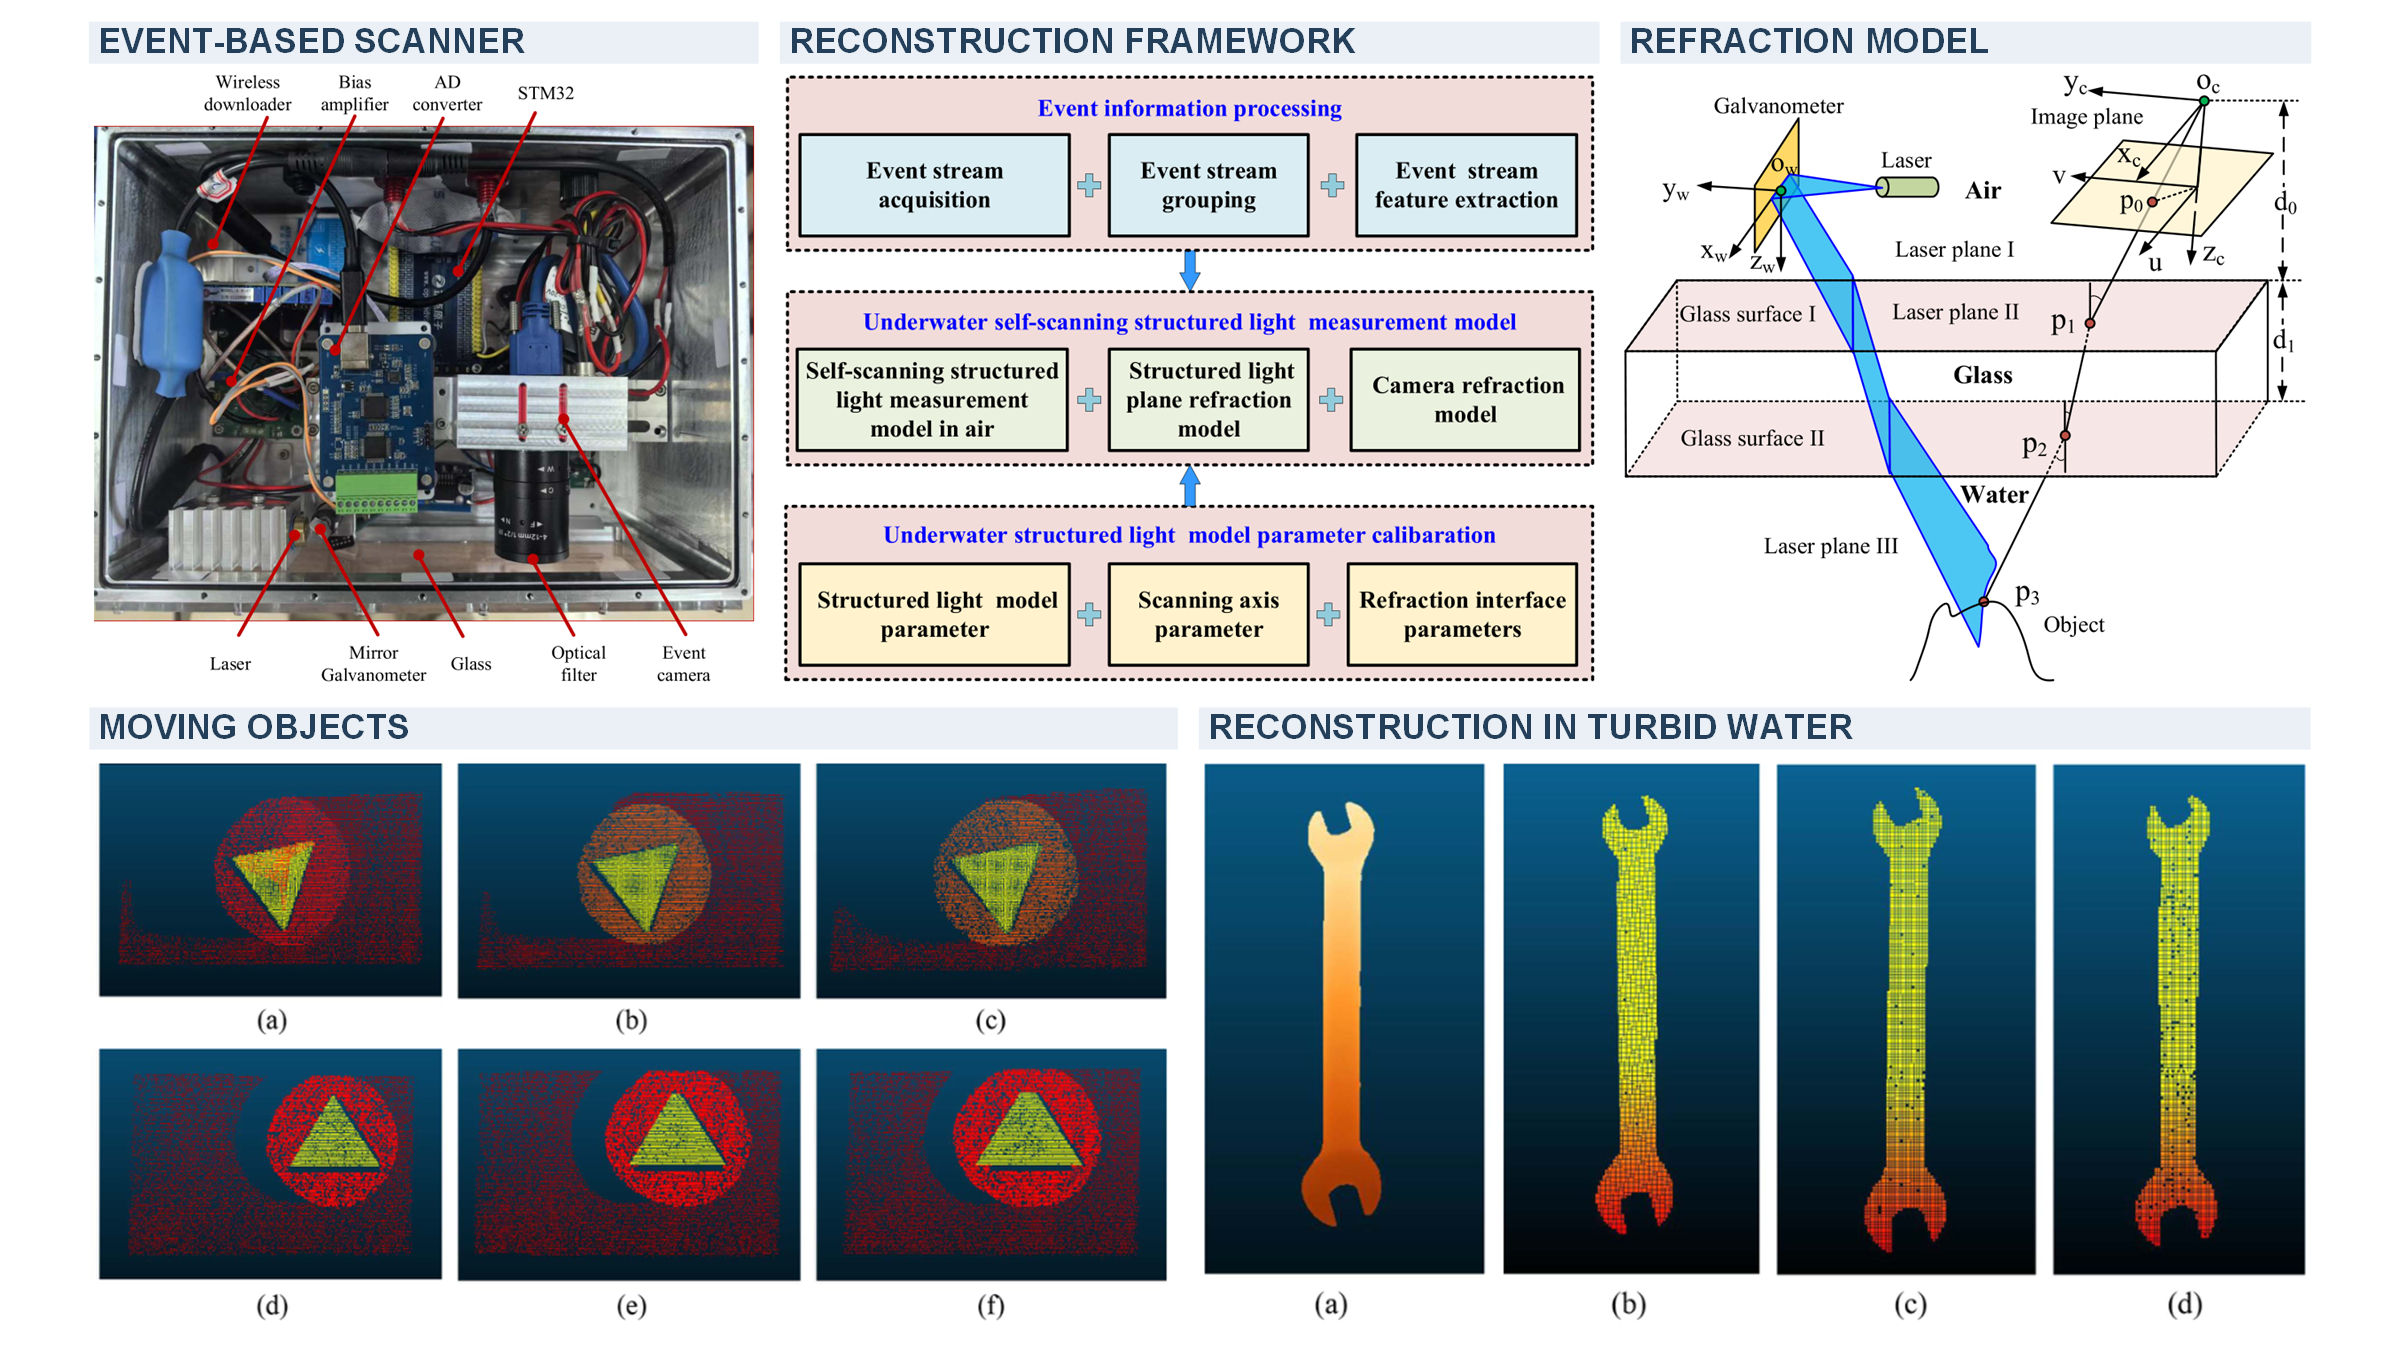
Event-Based Underwater Structured Light System for High-Speed 3-D Reconstruction
Combines asynchronous event sensing with a refraction-aware scanning-laser model to reconstruct moving underwater objects at up to 500 Hz.
Junfeng Fan, Yilin Jia, Yaming Ou*, Chao Zhou*, Zengguang Hou. IEEE/ASME Transactions on Mechatronics (TMech), 2026. [DOI]
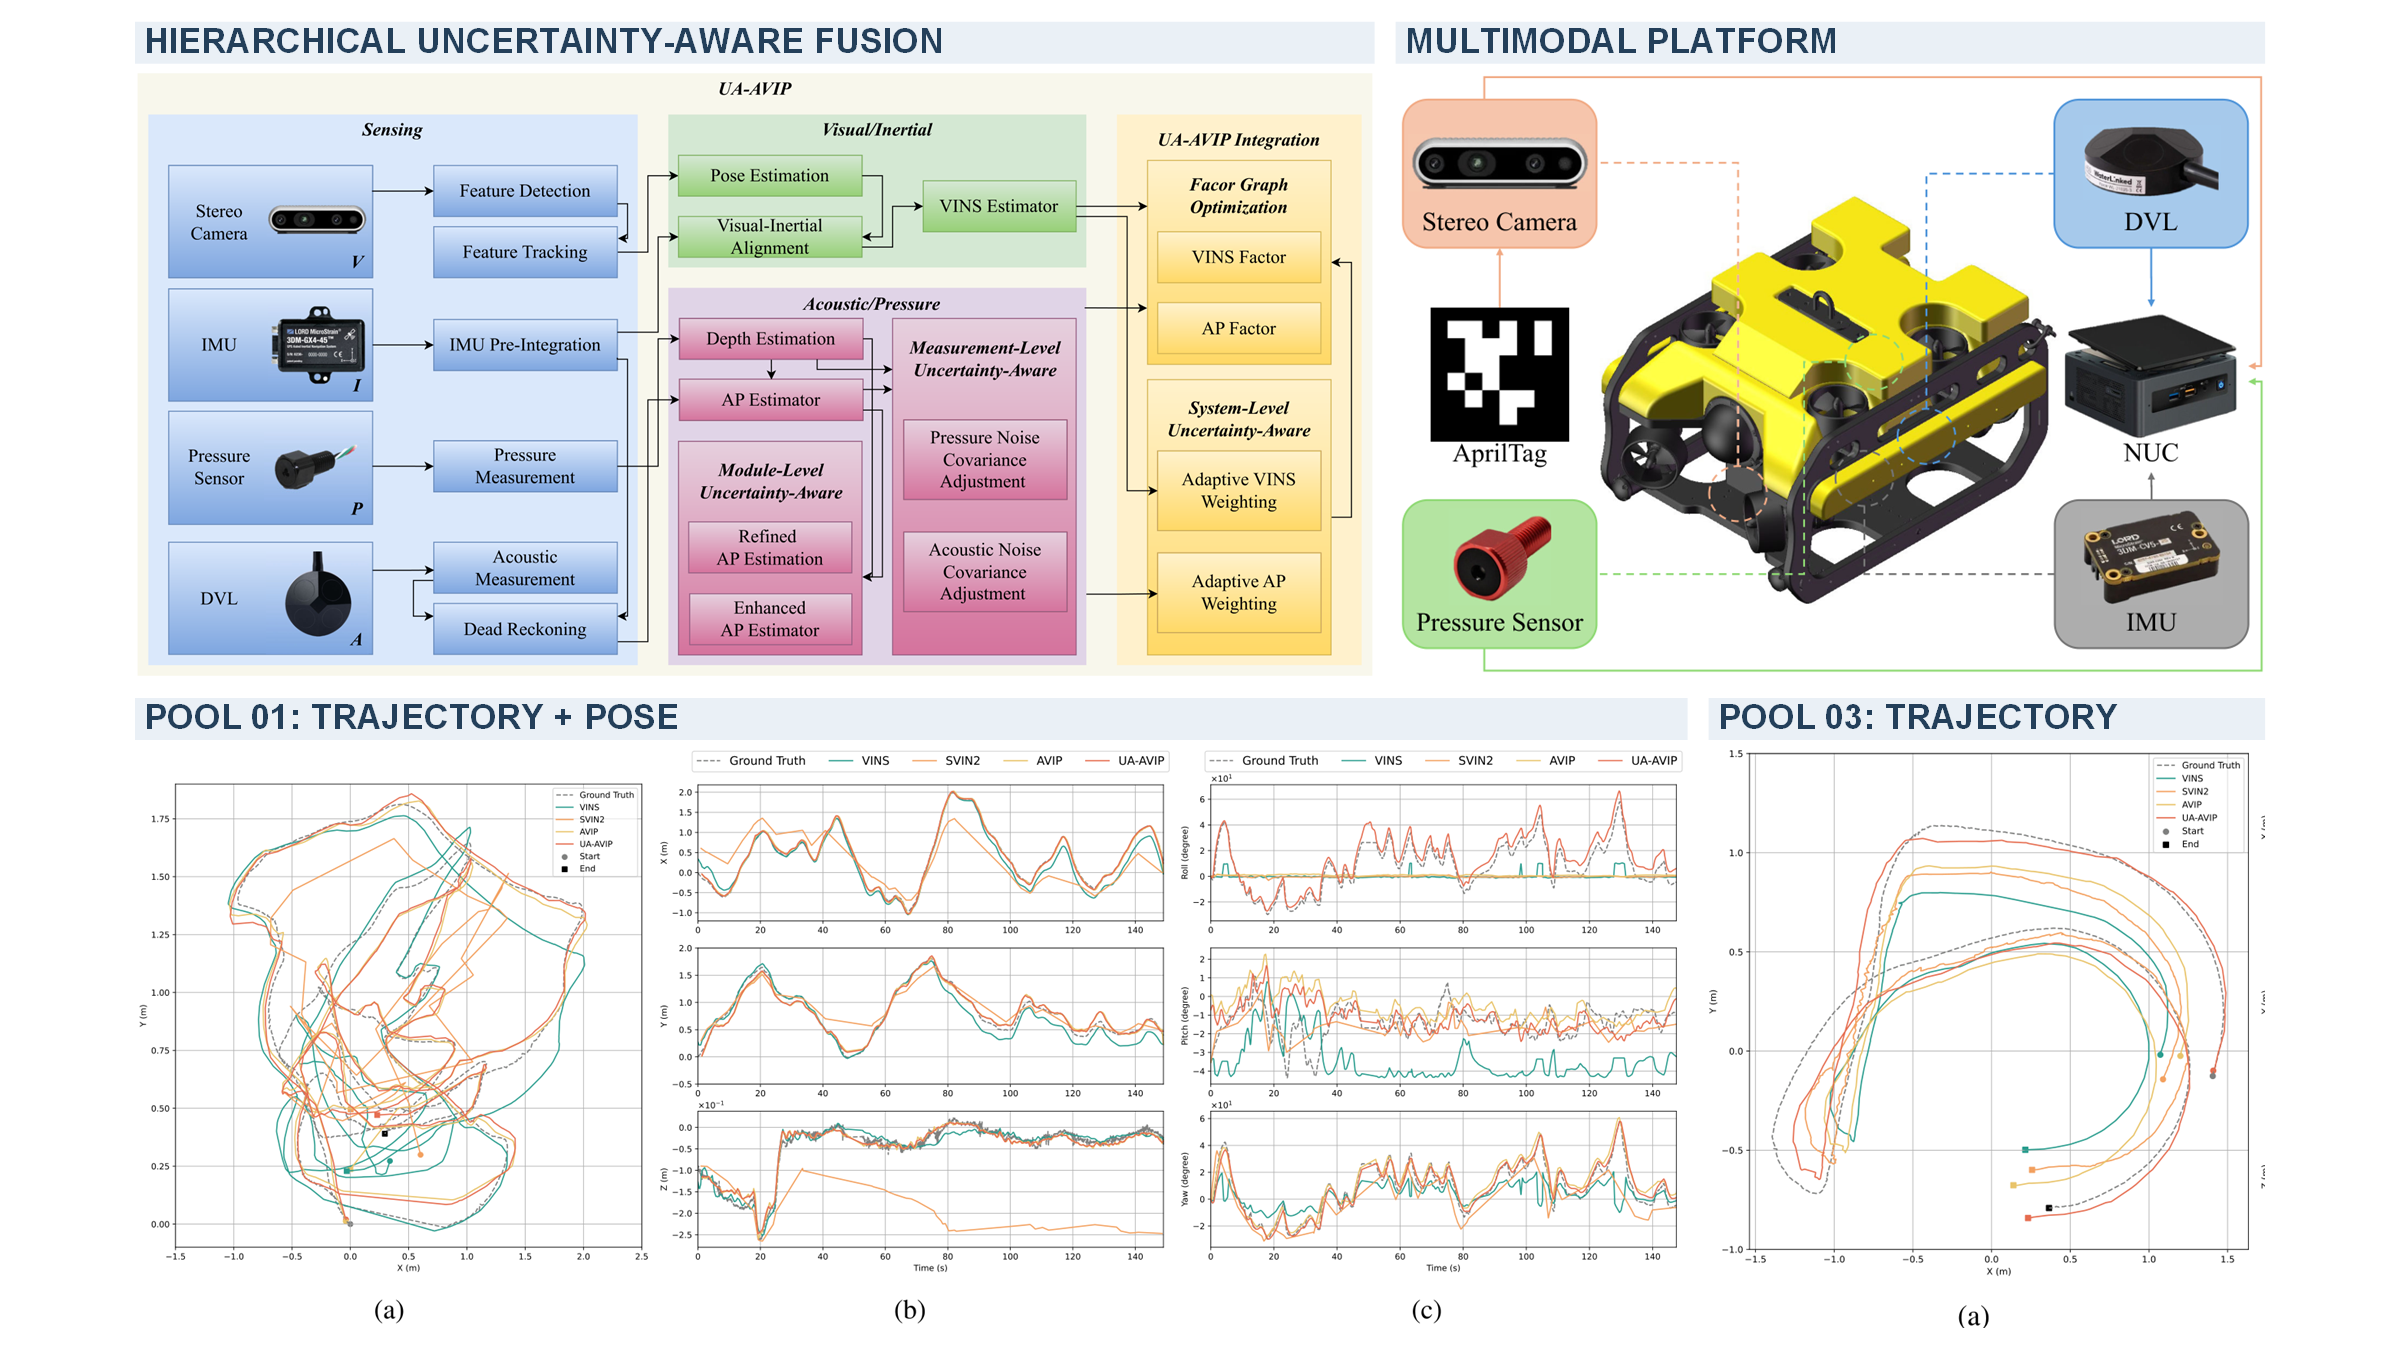
Multimodal Fusion for Underwater Localization Through Hierarchical Uncertainty Awareness
Models uncertainty at measurement, module, and system levels to adaptively fuse visual, inertial, acoustic, and pressure information for underwater localization.
Yuanbo Xue†, Yaming Ou†, Junfeng Fan*, Chao Zhou, Bing Wang*, Chih-Yung Wen. IEEE Transactions on Instrumentation and Measurement (TIM), 2026. [DOI] [Code]
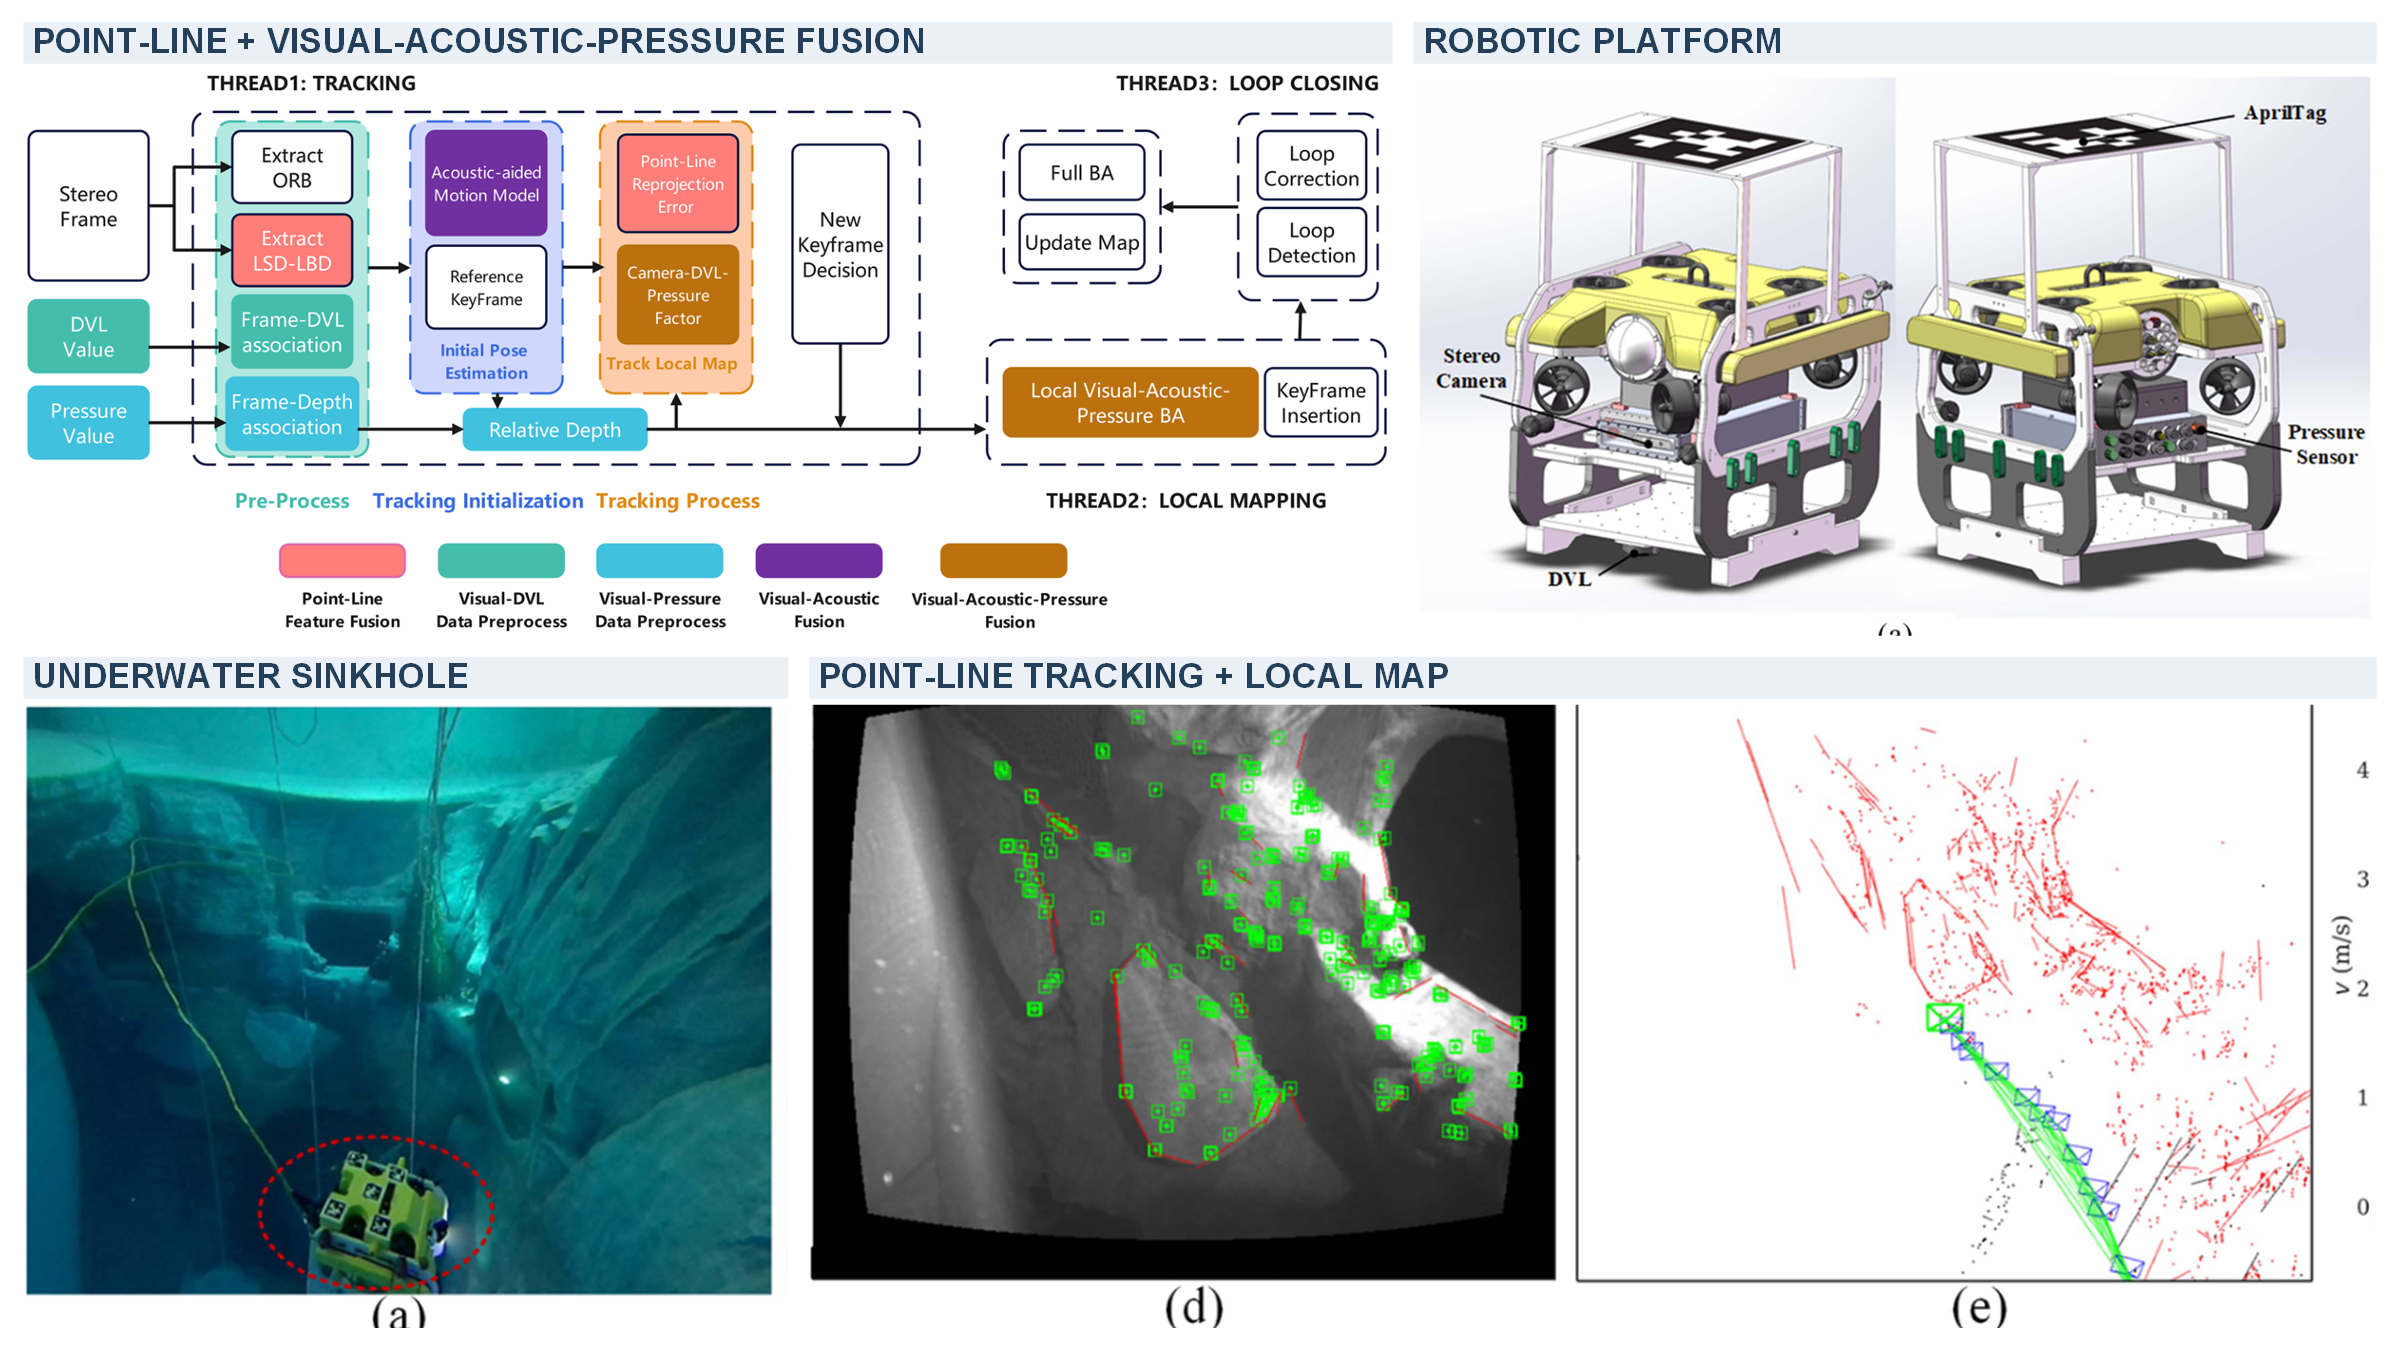
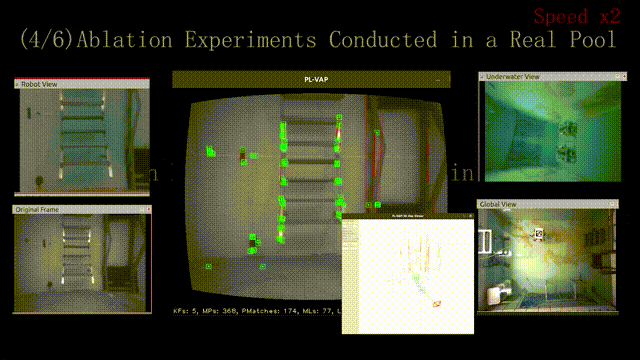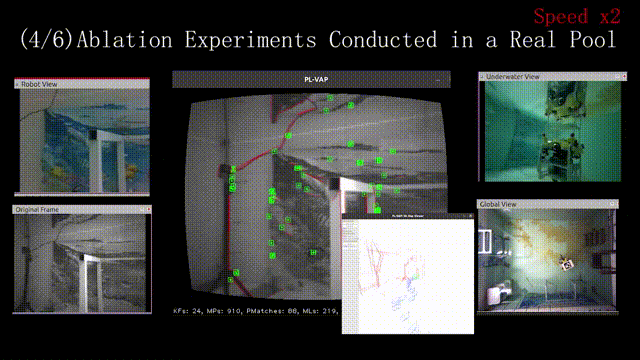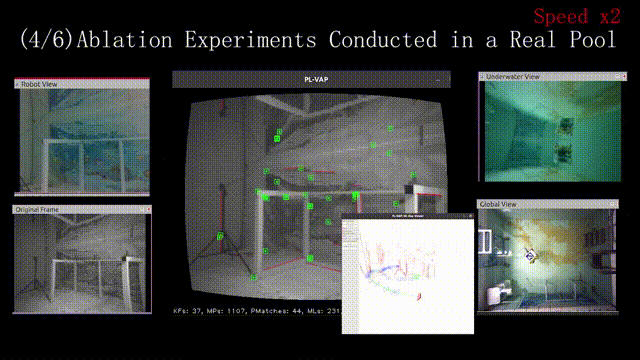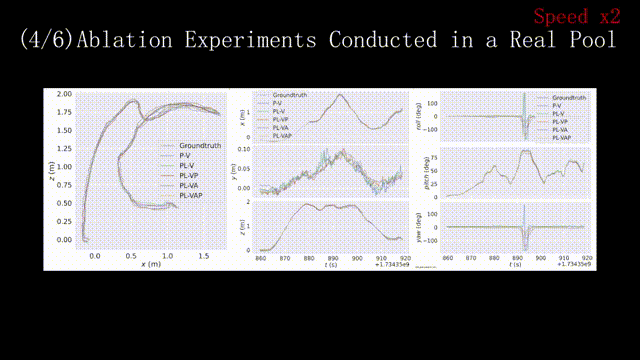
Jointly optimizes point and line features with DVL motion and pressure depth constraints to maintain reliable underwater localization in sparsely textured scenes.
Yaming Ou, Song Xia, Junfeng Fan*, Chao Zhou, Yupei Huang, Penghang Shuai, Yuanbo Xue, Zengguang Hou. IEEE/ASME Transactions on Mechatronics (TMech), 2025. [DOI] [Animation]
Hybrid-VINS: Underwater Tightly Coupled Hybrid Visual Inertial Dense SLAM for AUV
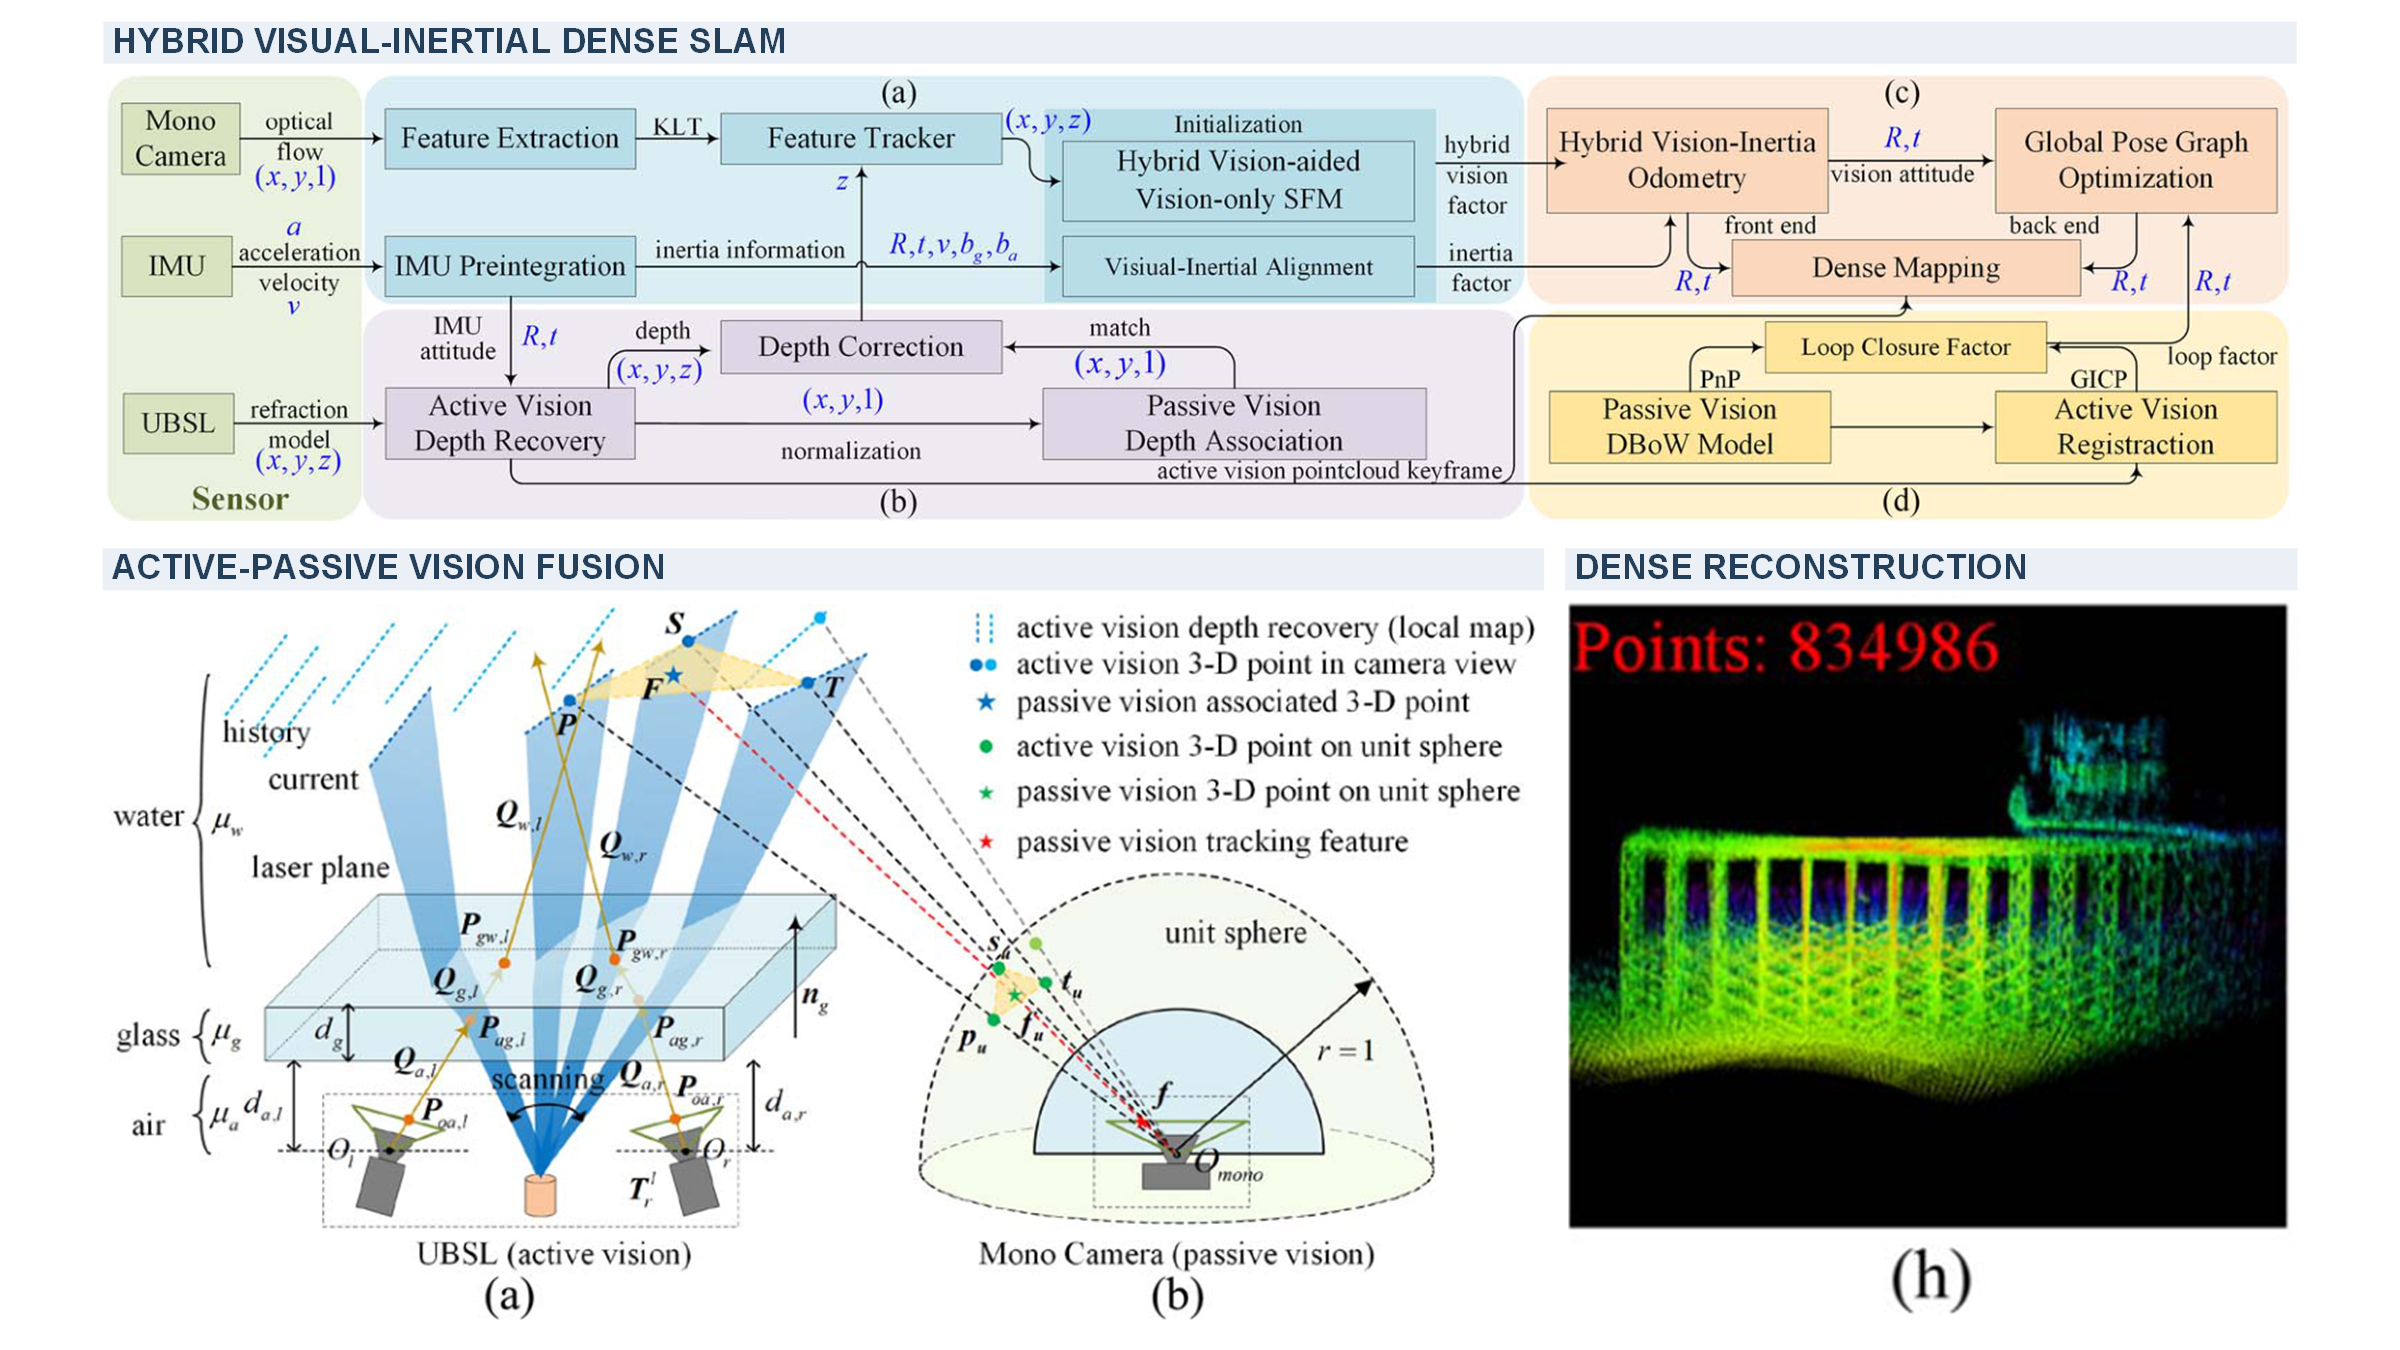
Uses active structured-light depth to strengthen passive visual-inertial initialization, feature tracking, and loop closure while producing dense underwater maps.
Yaming Ou, Junfeng Fan*, Chao Zhou, Pengju Zhang, Zeng-Guang Hou. IEEE Transactions on Industrial Electronics (TIE), 2025. [DOI] [Details] [Video]
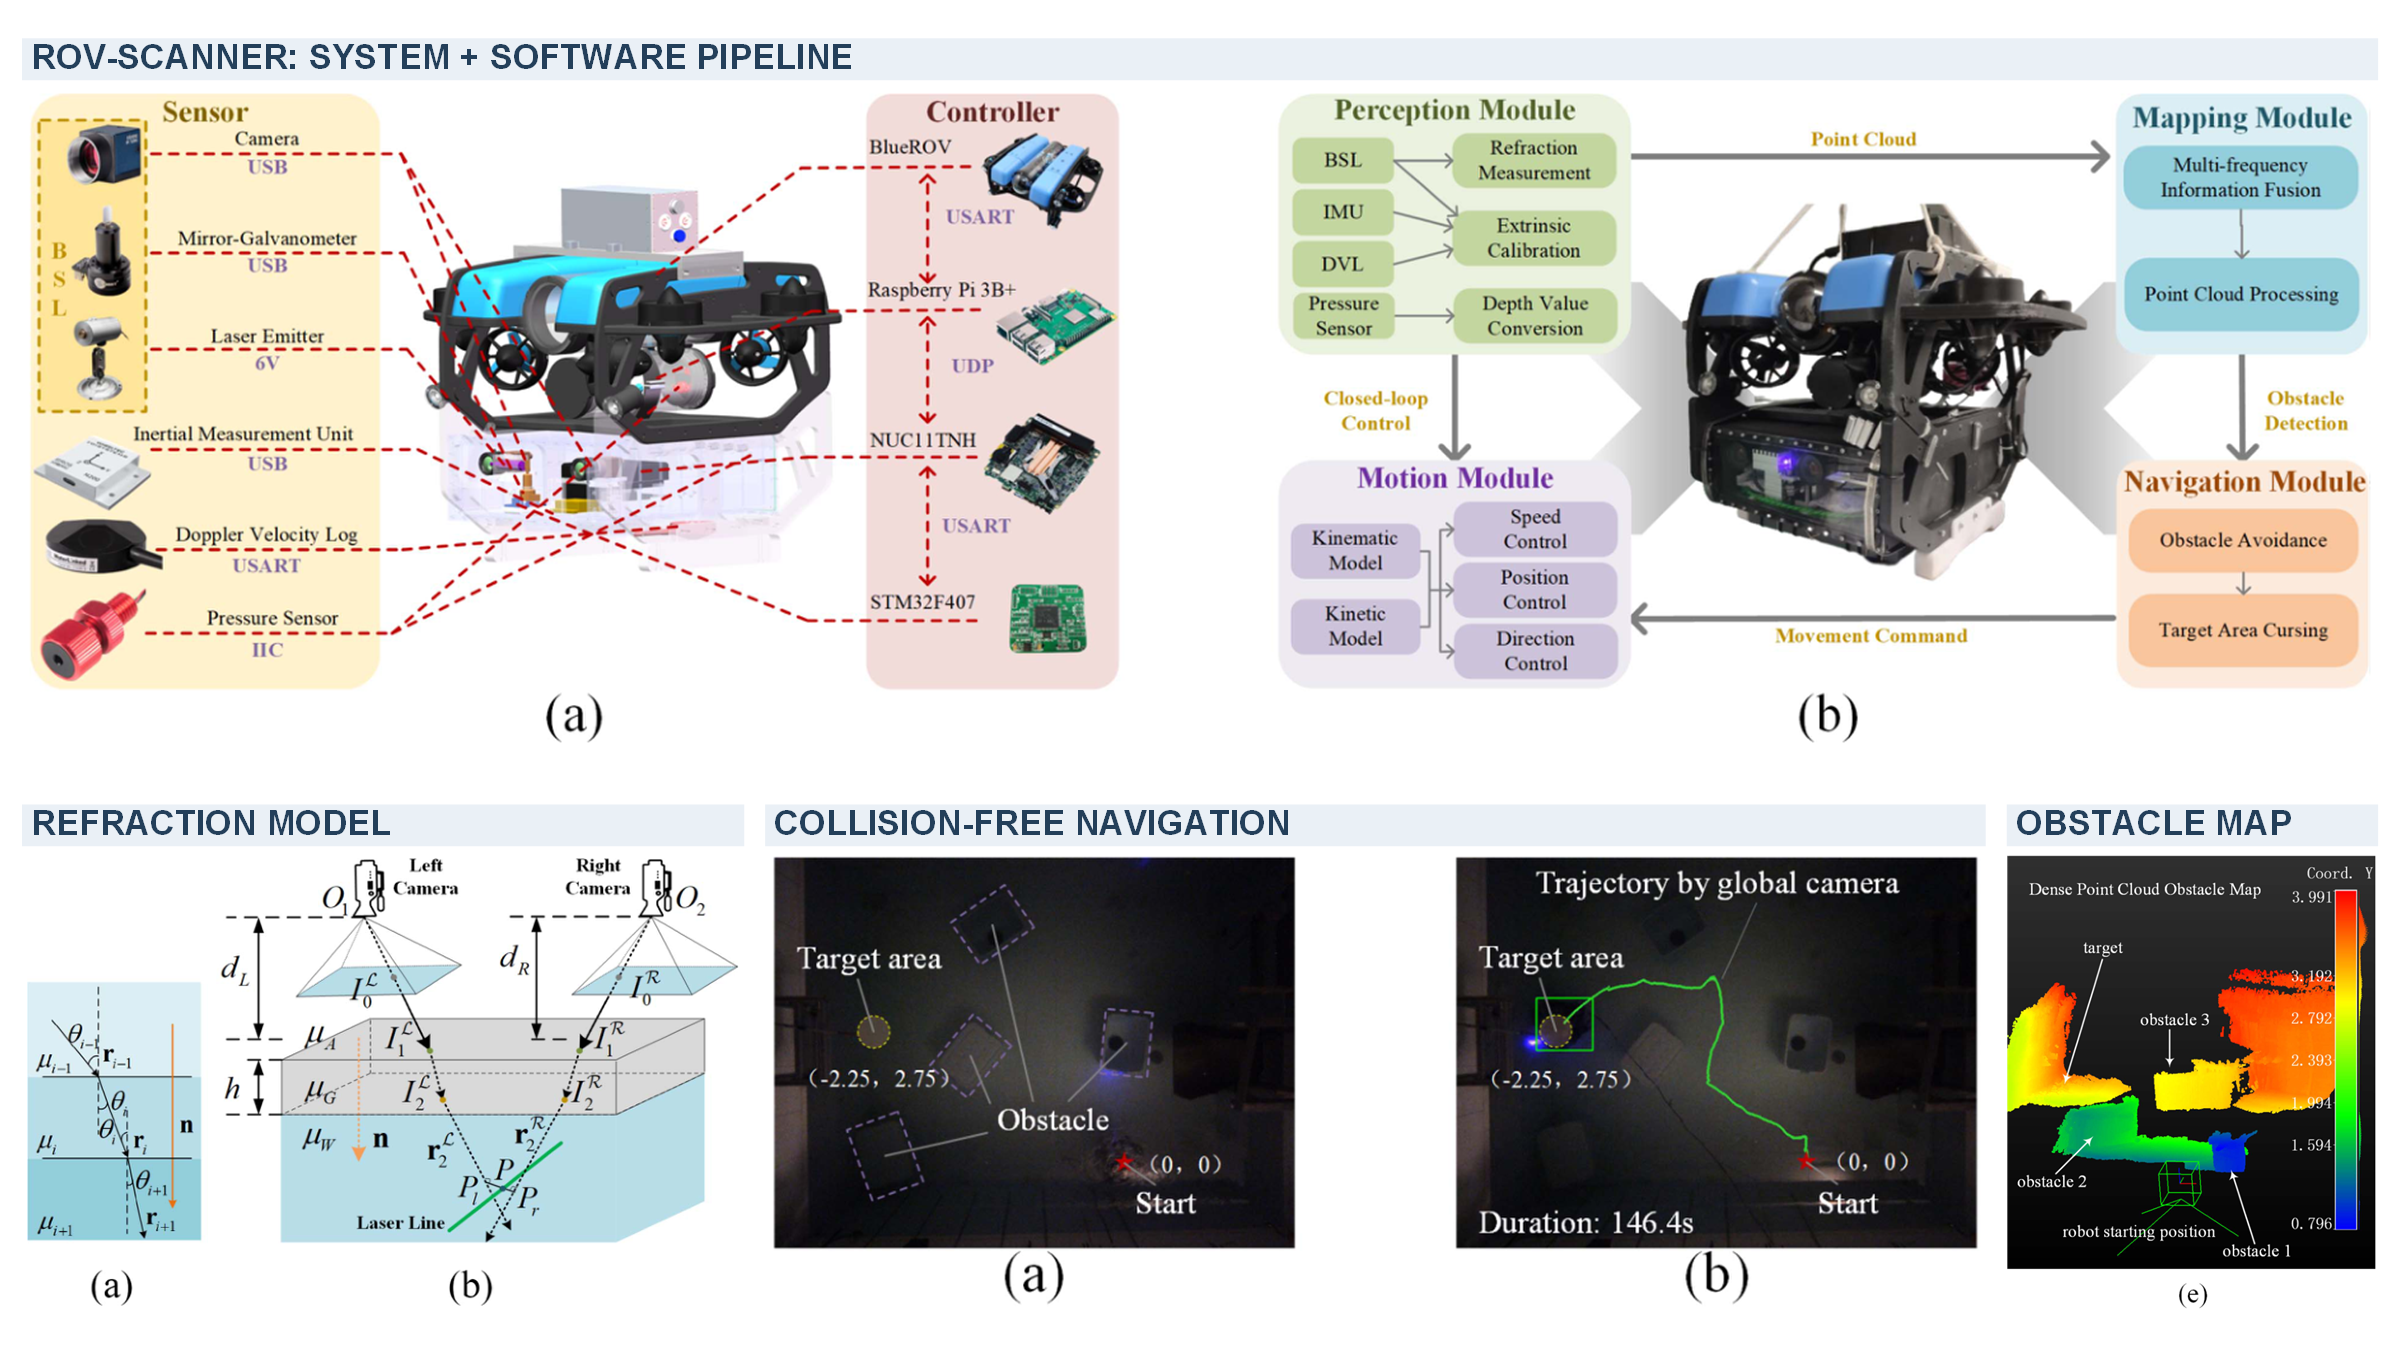
Integrates scanning binocular structured light, multirate sensor fusion, and air-water extrinsic calibration to enable simultaneous obstacle avoidance and dense mapping in dark water.
Yaming Ou, Junfeng Fan*, Chao Zhou*, Song Kang, Zhuoliang Zhang, Zeng-Guang Hou, Min Tan. IEEE Transactions on Systems, Man, and Cybernetics: Systems (TSMC), 2025. [DOI] [Paper] [Video]
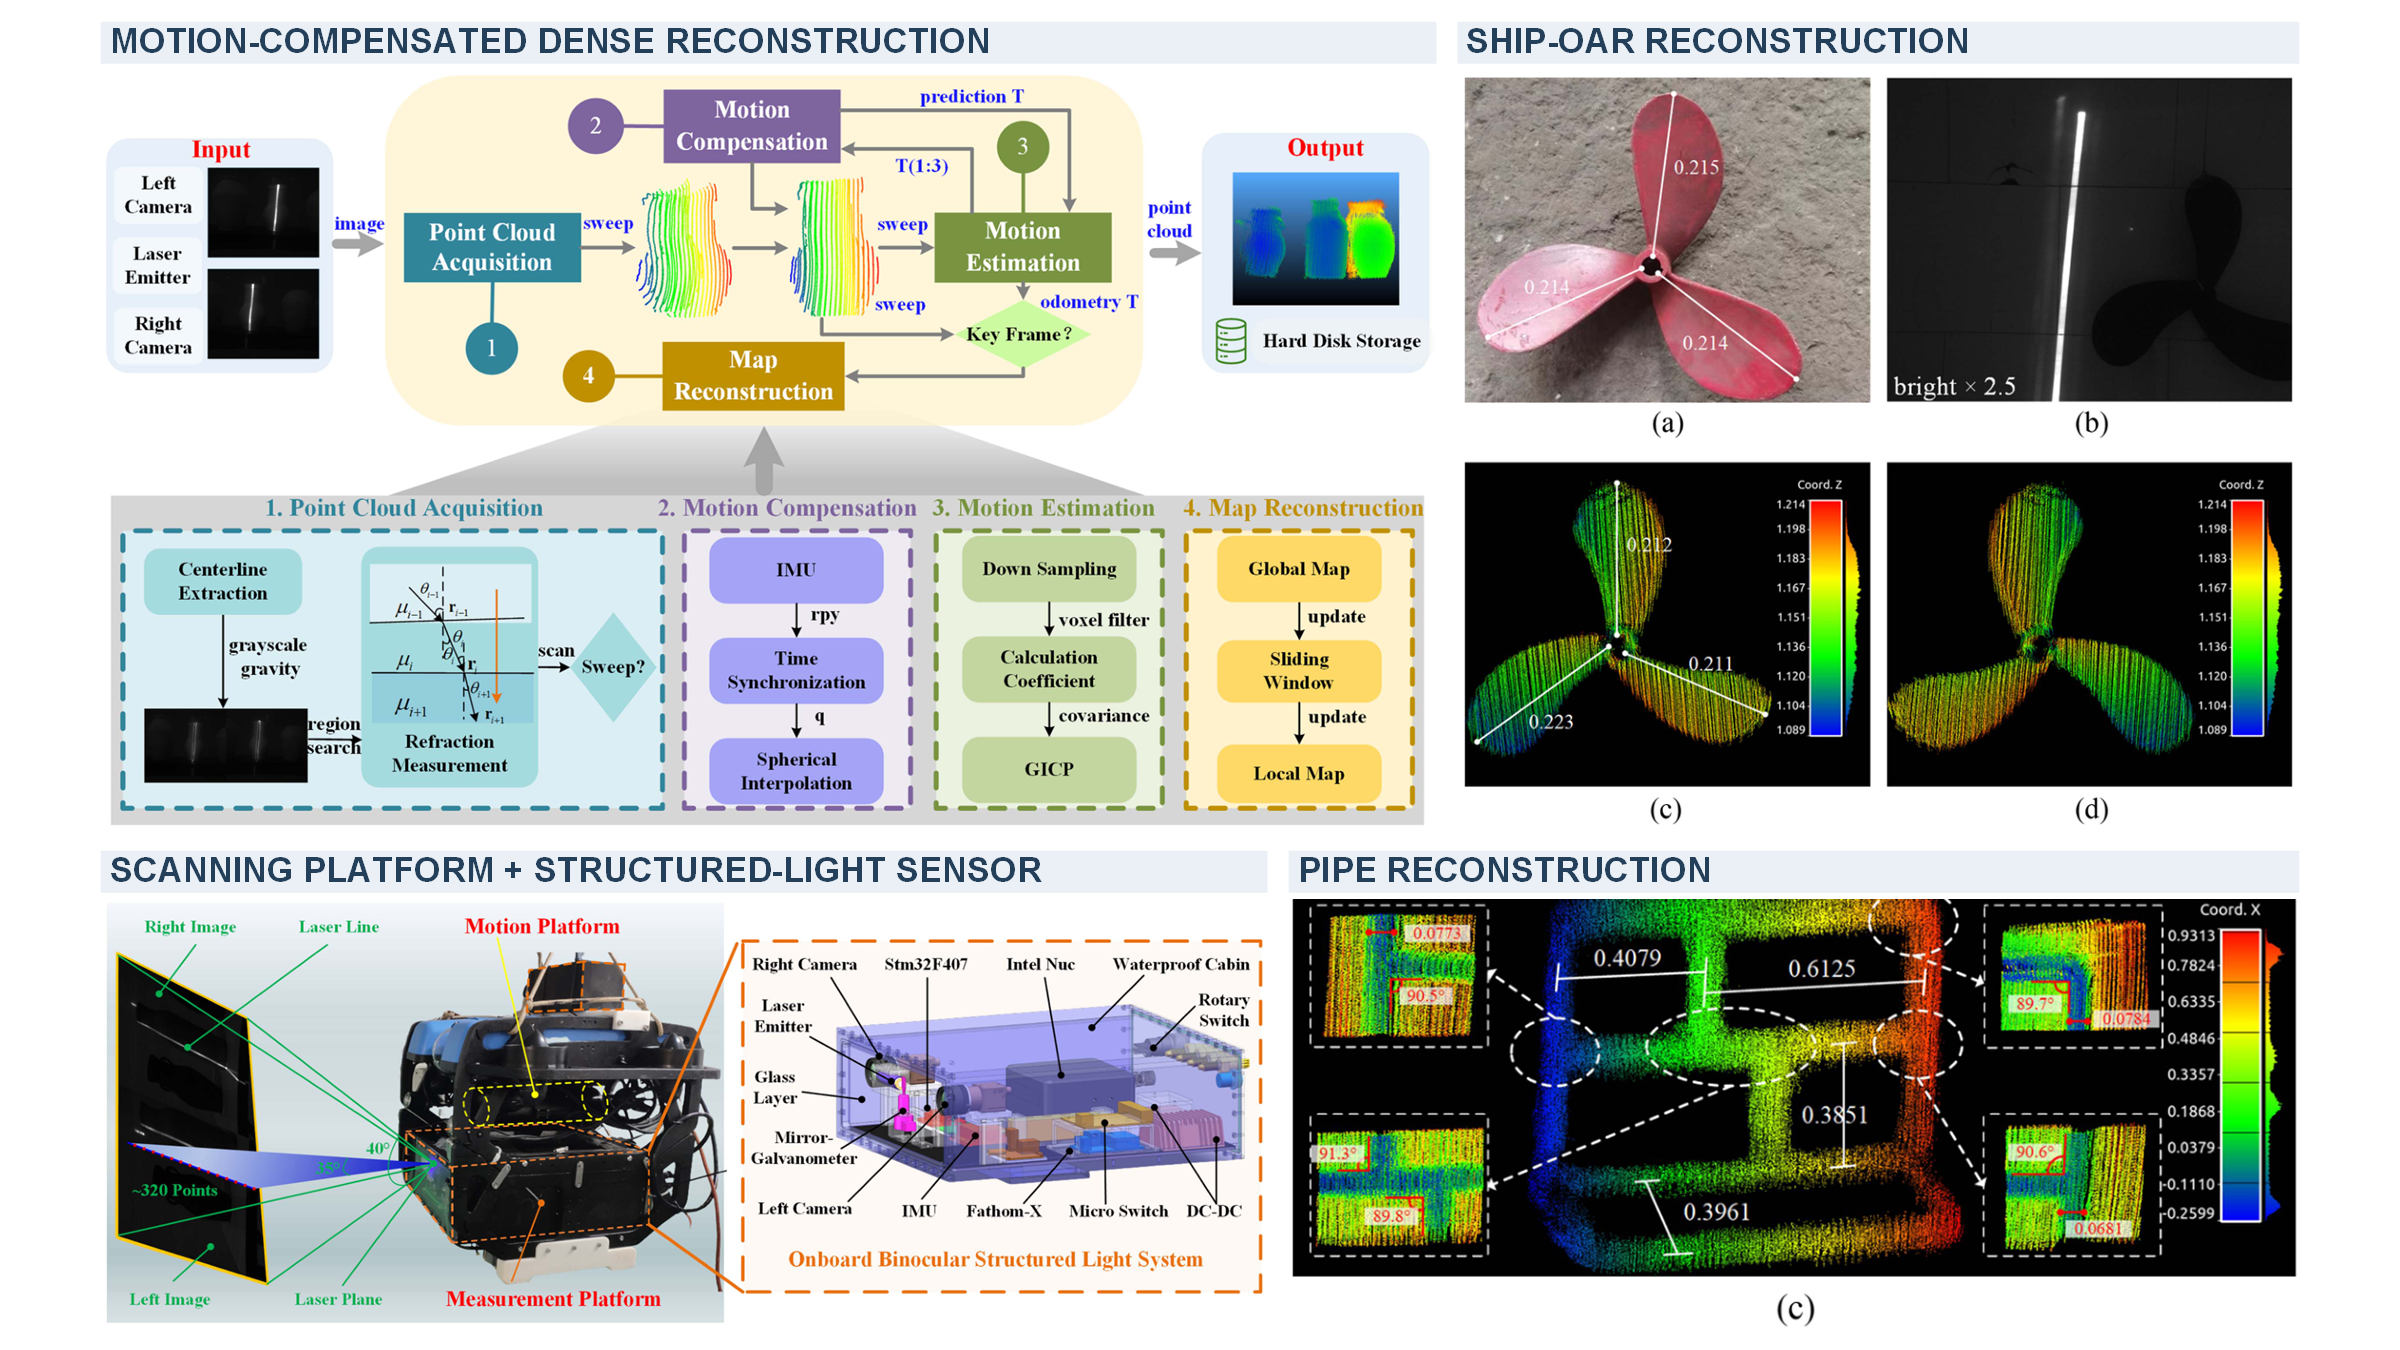
Compensates scan distortion using inertial measurements and a velocity model, then registers point clouds to reconstruct dense underwater geometry while the robot moves.
Yaming Ou, Junfeng Fan*, Chao Zhou*, Long Cheng, Min Tan. IEEE Transactions on Industrial Informatics (TII), 2024. [DOI] [Paper] [Video]
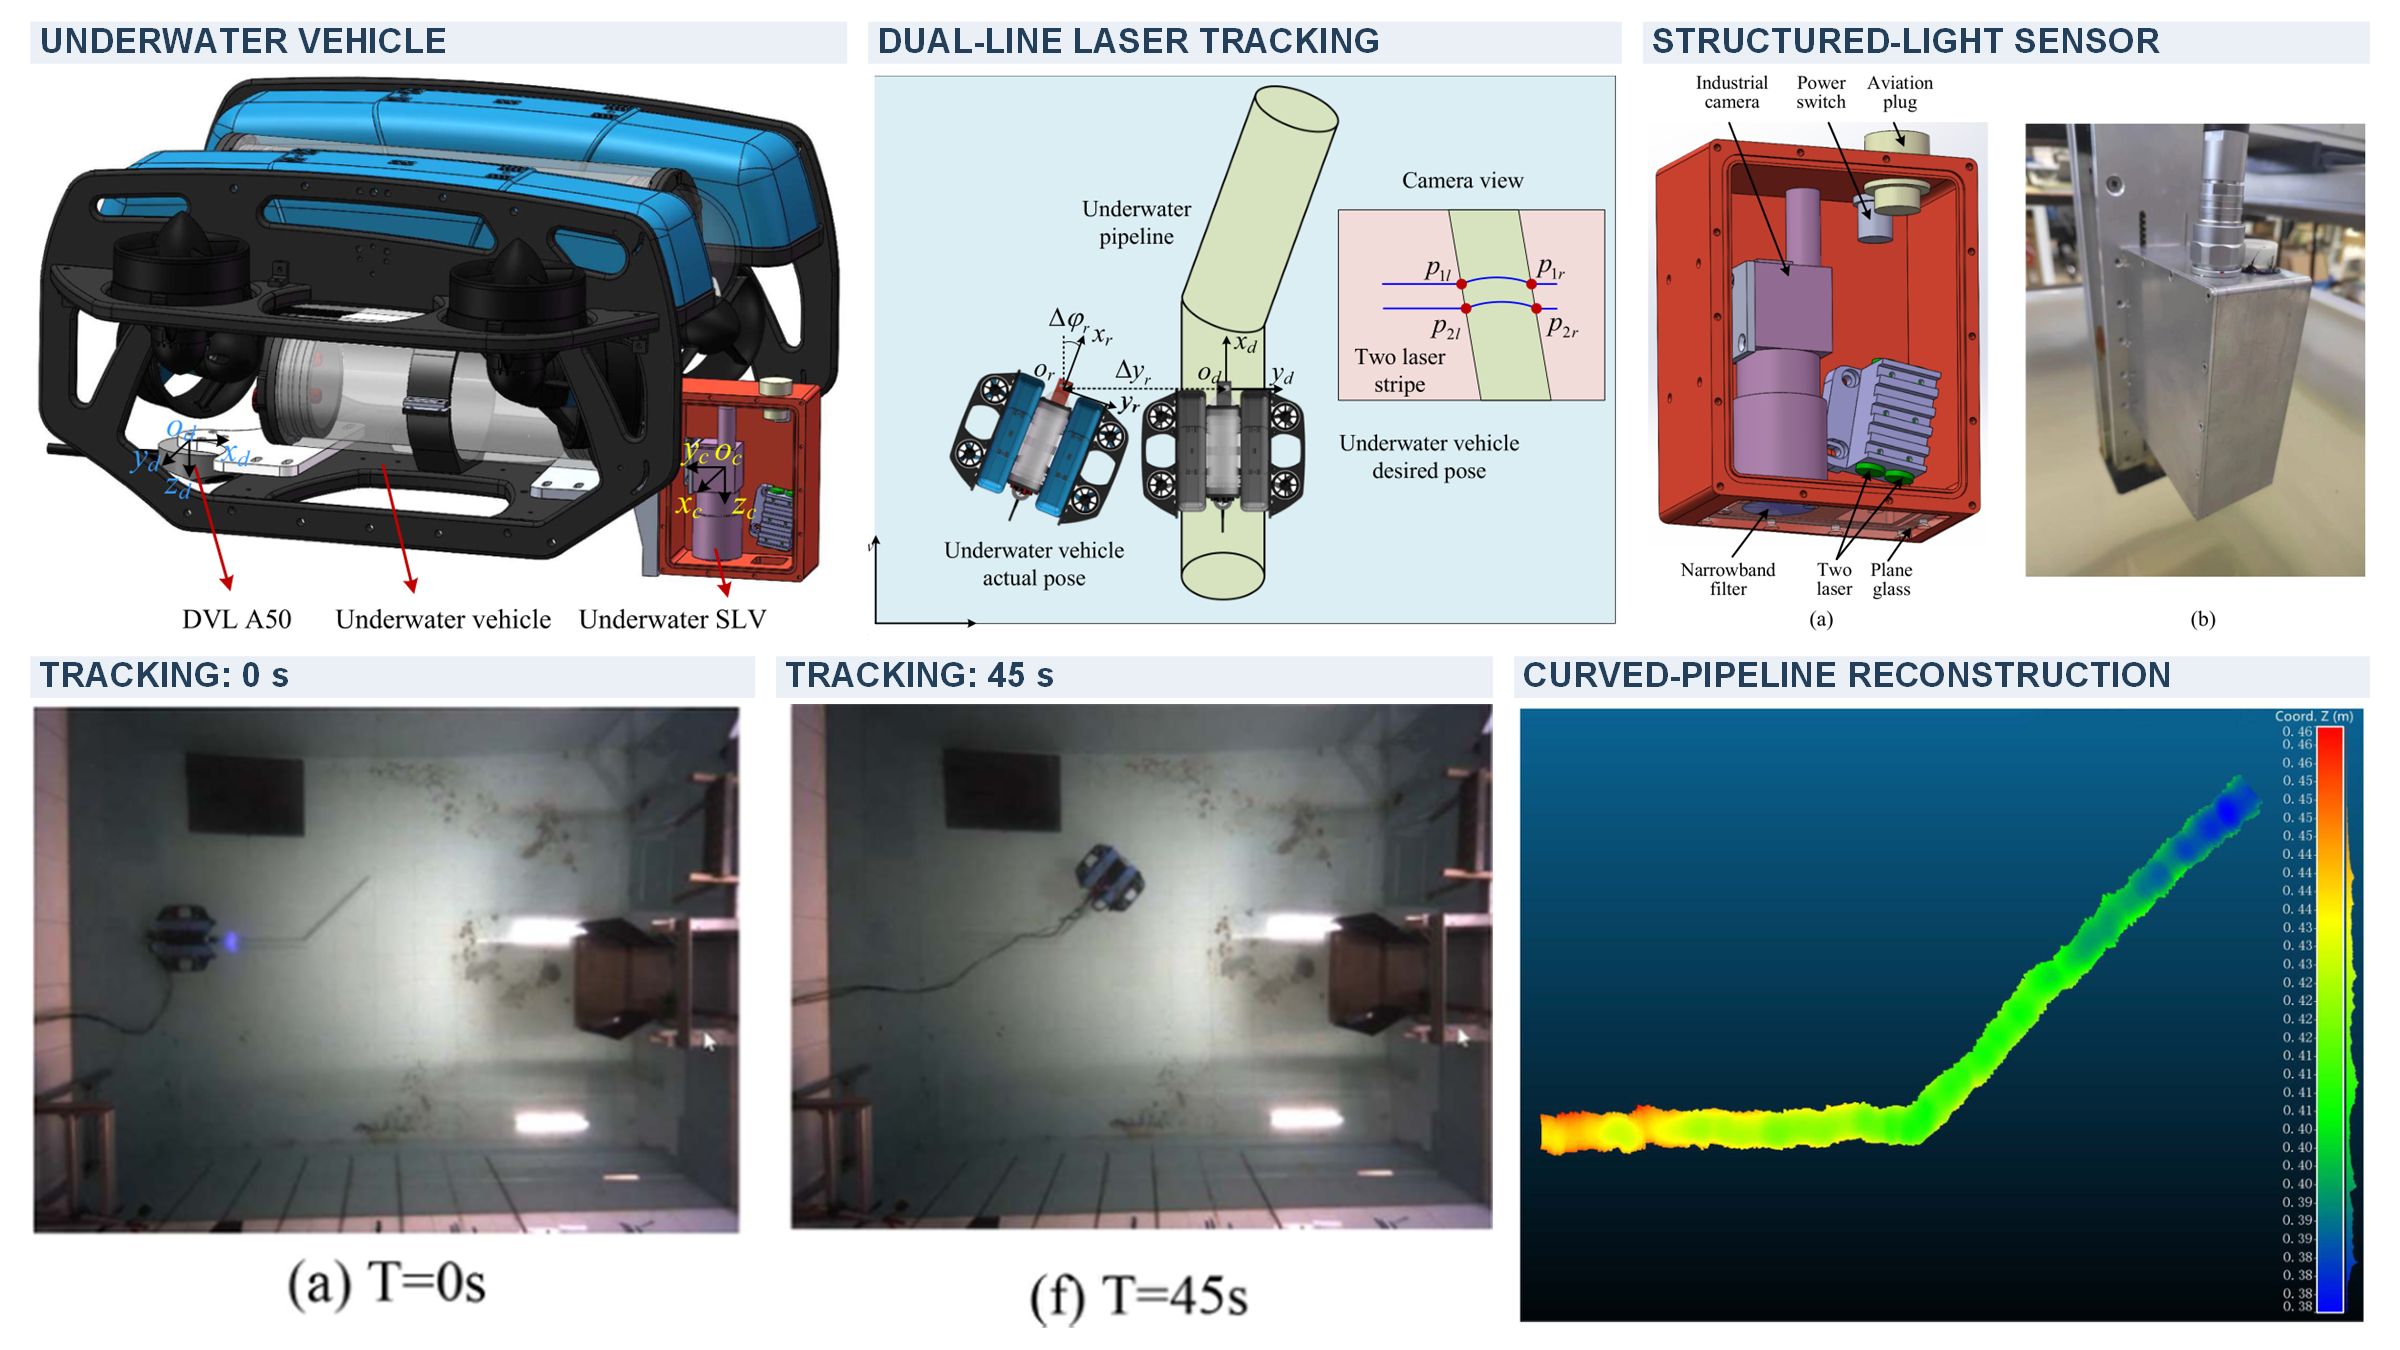
Structured Light Vision Based Pipeline Tracking and 3D Reconstruction Method for Underwater Vehicle
Recovers lateral, height, and heading offsets from dual laser stripes, enabling closed-loop pipeline tracking and DVL-assisted dense 3D reconstruction.
Junfeng Fan, Yaming Ou*, Xuan Li*, Chao Zhou, Zengguang Hou. IEEE Transactions on Intelligent Vehicles (TIV), 2024. [DOI] [Paper] [Video]
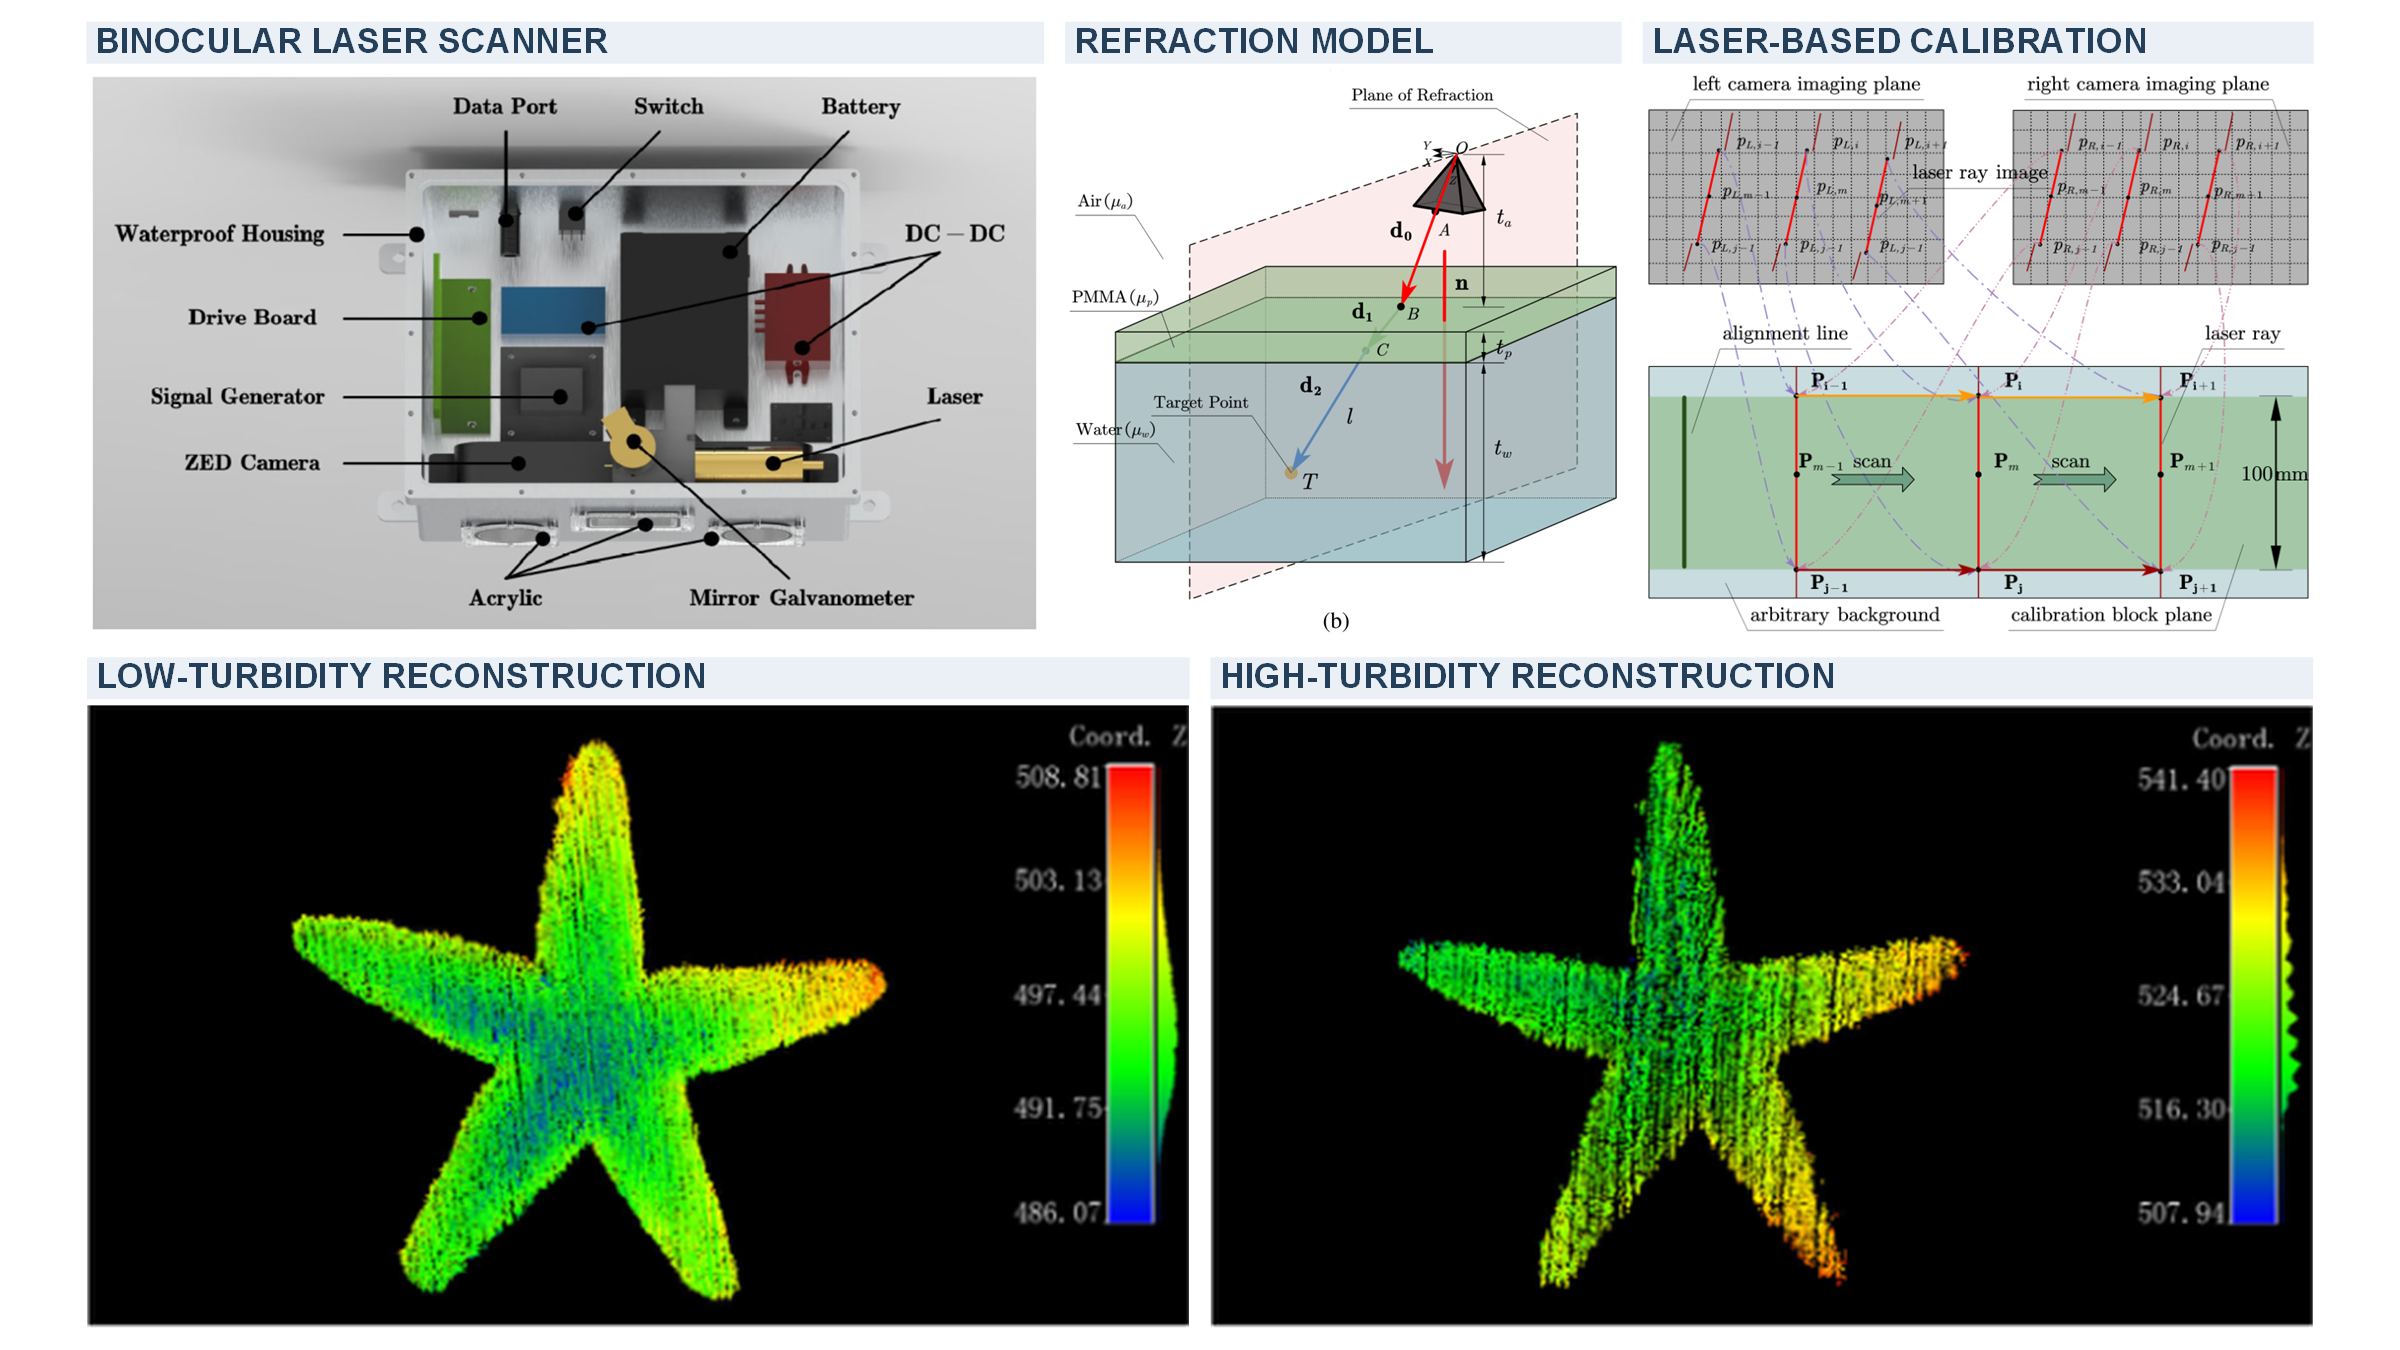
Combines refraction-aware binocular geometry with laser-constrained calibration to obtain precise underwater 3D reconstructions when conventional checkerboard calibration fails in low light.
Yaming Ou, Junfeng Fan*, Chao Zhou, Shifei Tian, Long Cheng, Min Tan. IEEE Transactions on Instrumentation and Measurement (TIM), 2023. [DOI] [Paper]
Other Publications
- Underwater Pipeline and Cable External Inspection Techniques: A Comprehensive Review, J. Fan, X. Liu, Y. Ou, et al. IEEE Transactions on Instrumentation and Measurement, 2026. [Paper]
- AEVINS: Tightly Coupled Acoustic-Event-Visual-Inertial Underwater Localization System in Complex Environments, X. Liu, J. Fan, Y. Ou, et al. IEEE/ASME Transactions on Mechatronics, 2026. [Paper]
- Underwater robot self-localization method using tightly coupled events, images, inertial, and acoustic fusion, J. Fan, X. Liu, Y. Ou, et al. IEEE Transactions on Industrial Electronics, 2025. [Paper]
- Mapping and localization in unknown underwater electric field using passive electric sense system, P. Shuai, H. Li, C. Zhou, Y. Ou, et al. IEEE Transactions on Instrumentation and Measurement, 2025. [Paper]
- Development, calibration, and image processing of underwater structured light vision system: A survey, J. Fan, X. Wang, C. Zhou, Y. Ou, et al. IEEE Transactions on Instrumentation and Measurement, 2023. [Paper]
- An underwater structured light vision calibration method considering unknown refractive index based on Aquila optimizer, X. Wang, J. Fan, S. Deng, Z. Wu, C. Zhou, Y. Ou, et al. IEEE Transactions on Instrumentation and Measurement, 2023. [Paper]
- Flexible artificial lateral line based on luminous flux for underwater velocity vector estimation, X. Wang, Z. Li, Z. Zhang, J. Fan, Y. Ou, et al. National Science Review, 2026. [Paper]
- Noise Suppression Method of Passive Electric Sense System for Robotic Shark, P. Shuai, H. Li, C. Zhou, J. Fan, X. Wang, Y. Ou, et al. IEEE Robotics and Automation Letters, 2026. [Paper]
- Optimization of a passive roll absorber for robotic fish based on tune mass damper, C. Zhu, C. Zhou, Q. Zou, J. Fan, Z. Zhang, Y. Ou, et al. Bioinspiration & Biomimetics, 2025. [Paper]
- A precise calibration method for the underwater binocular camera with unknown refractive index, H. Yang, S. Tian, J. Fan, Y. Han, C. Zhou, Y. Ou. IEEE Sensors Journal, 2023. [Paper]
- Tightly-coupled visual-DVL fusion for accurate localization of underwater robots, Y. Huang, P. Li, S. Yan, Y. Ou, et al. IEEE/RSJ International Conference on Intelligent Robots and Systems (IROS), 2023. [Paper]
- Fault Diagnosis for Robotic Fish Sensors Based on Spatial Domain Image Fusion and Convolution Neural Network, X. Fan, S. Deng, J. Fan, C. Zhou, Z. Wu, Y. Ou, et al. Chinese Control Conference (CCC), 2023. [Paper]
- Adaptive fusional localization for robot fish based on dynamic-weight fuzzy inference, Y. Fu, X. Liao, B. Lu, Q. Zou, Z. Zhang, Y. Ou, et al. China Automation Congress (CAC), 2021. [Paper]
- Data Calibration Algorithm for Artificial Lateral Line Sensor of Robotic Fish on Improved LSTM, Y. Ou, Z. Zhang, C. Zhou, B. Zhou. Chinese Control Conference (CCC), 2021. [Paper]
- UWLoc: Learning-Assisted Information Fusion for Underwater Localization via Dual-Odometry and Multi-Centric Calibration, Y. Xue, Y. Yang, X. Zhang, C. Zhou, Y. Ou, et al. SSRN Preprint 7149763, 2026. [Paper]
- TRACE: Coverage Path Planning for Unknown Environments Using Hierarchical Coverage Tree, Z. Shen, H. Liu, G. Wang, S. Zhao, D. Zhou, Y. Ou, et al. arXiv:2609.21777, 2026. [Paper]
- A Hierarchical Coverage Path Planning Algorithm for Unknown Environments, Z. Shen, H. Liu, G. Wang, H. Ma, Y. Ou, et al. arXiv:2609.12595, 2026. [Paper]
- Learning-Based Motion Planning for Dynamic Environments: From Foundational Algorithms to Emerging Paradigms, Z. Shen, S. Gupta, S. Zhao, D. Zhou, G. Wang, R. Cheng, Y. Ou, et al. arXiv:2608.00625, 2026. [Paper]
- Coverage Path Planning: Classical Foundations, Recent Advances, and Future Directions, Z. Shen, S. Gupta, S. Zhao, D. Zhou, G. Wang, Z. Ren, Y. Ou, et al. arXiv:2607.10649, 2026. [Paper]
- Motion Planning in Dynamic Environments: A Survey from Classical to Modern Methods, Z. Shen, Y. Ou, S. Gupta, et al. arXiv:2606.02677, 2026. [Paper]
- An underwater, fault-tolerant, laser-aided robotic multi-modal dense SLAM system for continuous underwater in-situ observation, Y. Ou, J. Fan, C. Zhou, et al. arXiv:2504.21826, 2025. [Paper]
🎖 Honors and Awards
- 2026: CAS President’s Excellence Award (中国科学院院长优秀奖)
- 2025: Three Good Student Model of UCAS (top 1%)
- 2024: UCAS PhD International Cooperation Program (one spot per institute)
- 2024: China PhD National Scholarship (博士研究生国家奖学金)
- 2024: Outstanding Student Leader Award of UCAS (top 2%)
- 2023: PhD Experimental Class of CASIA (8/276)
- 2022: China ICV Algorithms Challenge Competition — 1st place
- 2022: Three Good Students Award of UCAS
- 2021: Data Application Innovation and Entrepreneurship Competition — merit award (9/453)
- 2021: Outstanding Graduate Award of Southeast University
- 2020: National College Students Intelligent Vehicle Competition — national 2nd prize
- 2020: China National Inspiration Scholarship
- 2019: RoboCup Robotics World Cup, China Region — national 1st prize
- 2019: National College Students Electronic Design Competition — national 2nd prize
- 2019: 10th Robot Competition of Jiangsu Province — provincial 1st prize
- 2019: Three Good Students Award of Southeast University
- 2018: 9th Robot Competition of Jiangsu Province — provincial 1st prize
- 2016: High School Mathematics Olympiad, Anhui Province — provincial 2nd prize
📖 Services
- Associate Editor of Advanced Bionics (ABS)
- Associate Editor of ICRA 2027
- Reviewer of IEEE TRO, TIE, TII, TIV, TASE, IoT Journal, and Sensors Journal
- Reviewer of Science China Information Sciences, Knowledge-Based Systems, Results in Engineering, and CIT
- Reviewer of ICRA 2026
🎓 Educations
- 2021.09 - 2026.06, Institute of Automation, Chinese Academy of Sciences (CASIA), and School of Artificial Intelligence, University of Chinese Academy of Sciences (UCAS), Ph.D.
- 2017.09 - 2021.06, Southeast University, B.E. in Robotics Engineering. Materials Science and Engineering (2017–2018); School of Automation (2018–2021).
💼 Experiences
- 2026.06 - 2029.06, School of Artificial Intelligence, University of Chinese Academy of Sciences, Research Fellow.
- 2025.03 - 2026.03, Robotics Institute, Carnegie Mellon University, Visiting Scholar.